

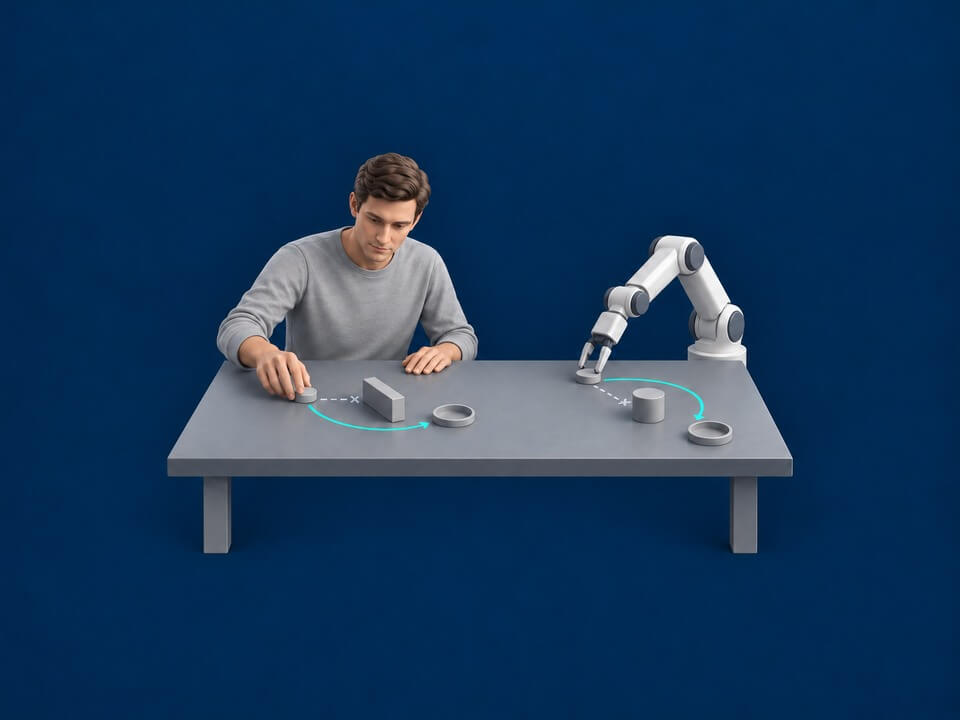
We study how robots can learn from the way people acquire skills—including exploration, errors, and strategy changes—combining demonstrations, language, and movement to transfer knowledge across bodies and tasks.
We study how robots can learn from the way people acquire skills—including exploration, errors, and strategy changes—combining demonstrations, language, and movement to transfer knowledge across bodies and tasks.